Senior Research Scientist at Noah's Ark Lab, with Amir Rasouli at Huawei Research Canada. I have been working on motion prediction for autonomous vehicles, with a focus on scene understanding [ICCV 2023], causal reasoning and domain generalization [CVPR 2024, ECCV 2024, IV 2024], and trustworthiness [CVPR 2024, ICRA 2024].
Mozhgan Pourkeshavarz
> Hello, World!
I am a second-year PhD student at the University of Toronto, supervised by Prof. Nicholas Rhinehart and affiliated with the Robotics Institute. My research focuses on generative world models and model-based control for autonomous driving, spanning closed-loop traffic simulation and end-to-end driving policies.
Prior to my PhD studies, I was a Research Scientist at Noah's Ark Lab, Huawei Research Canada, working with the Embodied AI (EAI) team under the supervision of Dr. Amir Rasouli. My research focused on motion prediction for autonomous driving. I earned my master’s degree in Computer Science, specializing in Artificial Intelligence and Robotics, with highest honors from Shahid Beheshti University in 2021. I also had the opportunity to work with Prof. Mohammad Sabokrou.
G. Scholar /
LinkedIn
I am open to collaborations, feel free to reach out!
m.pourkeshavarz at gmail dot com
Nov-2024
📚 I am looking for a PhD position in the field of autonomous driving.Sep-2024
I’ll be attending ECCV 2024 in Milan. If you’ll be there too and share an interest in autonomous driving, I’d be happy to connect!July-2024
🚀 our paper "DySeT: a Dynamic Masked Self-distillation Approach for Robust Trajectory Prediction" has been accepted to ECCV 2024!July-2024
I’m heading to ICML 2024 in Vienna!Feb-2024
🔥 I'm happy to share the acceptance of two papers at CVPR 2024!July-2023
📢 Excited to share that our paper "Learn TAROT with MENTOR: A Meta-Learned Self-supervised Approach for Trajectory Prediction" got accepted to ICCV 2023!Jun-2023
I’ll be attending CVPR 2023 in beautiful Vancouver!2022.09 - Present

2021.09 - 2022.08

Machine Learning Engineer at MTL.ai. I developed object detection and segmentation methods for real-time virtual advertisement software in live sports broadcasts.
2020.09 - 2021.09

Research Assistant at IPM Institute For Research In Fundamental Sciences, supervised by Mohammad Sabokrou. I Researched methods to address catastrophic forgetting in the incremental training of deep neural networks, with applications in computer vision [ICLR 2022].
AutoWorld: Learning Multi-Agent Traffic Simulation with Self-Supervised World Models
Mozhgan Pourkeshavarz, Tianran Liu, Nicholas Rhinehart
arXiv preprint (arXiv 2026)
OccSim: Multi-kilometer Simulation with Long-horizon Occupancy World Models
Tianran Liu, Shengwen Zhao, Mozhgan Pourkeshavarz, Weican Li, Nicholas Rhinehart
arXiv preprint (arXiv 2026)
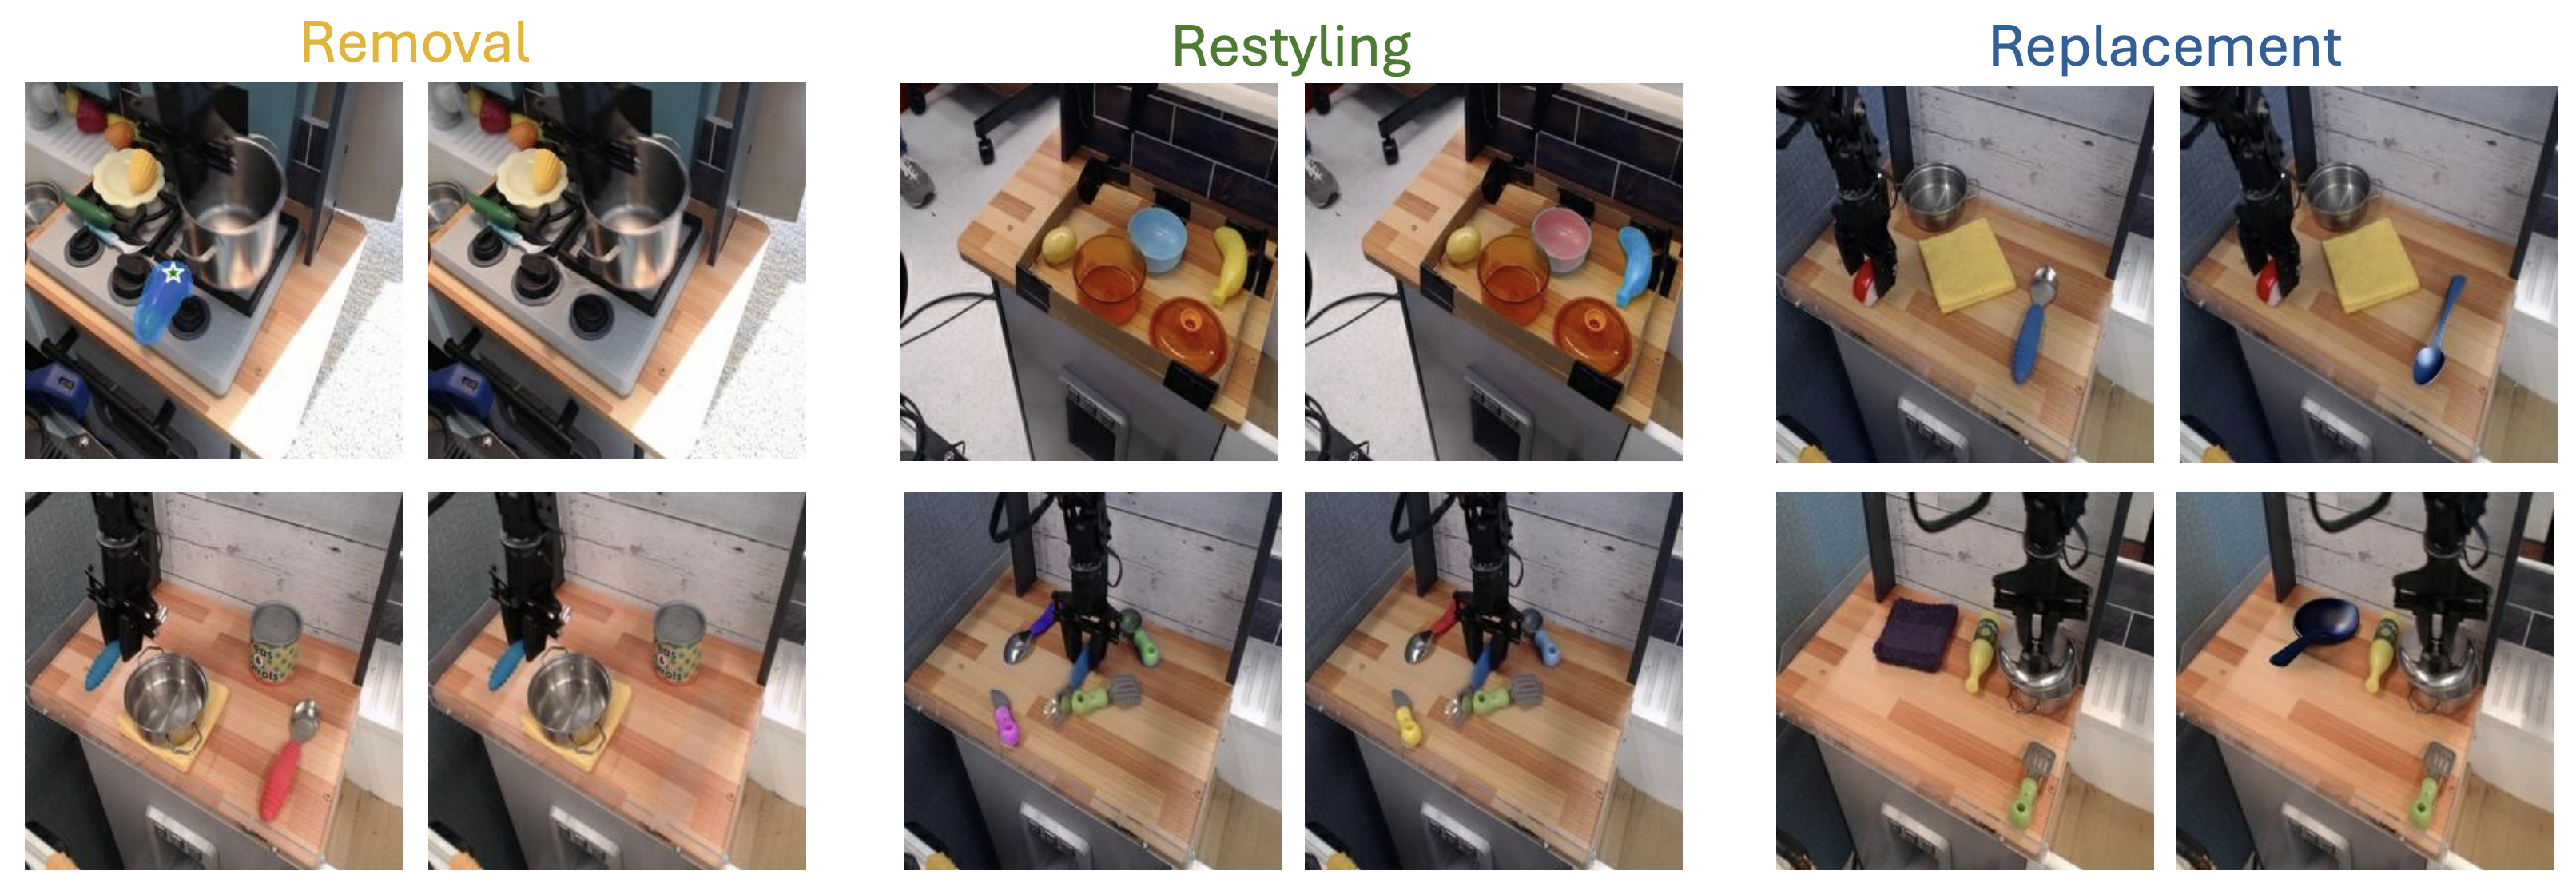
Improving Robotic Manipulation Robustness via NICE Scene Surgery
Sajjad Pakdamansavoji, Mozhgan Pourkeshavarz, Adam Sigal, Zhiyuan Li, Rui Heng Yang, Amir Rasouli
International Conference on Robotics and Automation (ICRA 2026)

DySeT: A Dynamic Masked Self-distillation Approach for Robust Trajectory Prediction
Mozhgan Pourkeshavarz, Junrui Zhang, Amir Rasouli
European Conference on Computer Vision ( ECCV 2024 )

Adversarial Backdoor Attack by Naturalistic Data Poisoning on Trajectory Prediction in Autonomous Driving
Mozhgan Pourkeshavarz, Mohammad Sabokrou, Amir Rasouli
Conference on Computer Vision and Pattern Recognition (CVPR 2024)

CaDeT: a Causal Disentanglement Approach for Robust Trajectory Prediction in Autonomous Driving
Mozhgan Pourkeshavarz, Junrui Zhang, Amir Rasouli
Conference on Computer Vision and Pattern Recognition (CVPR 2024)

Criteria: a new benchmarking paradigm for evaluating trajectory prediction models for autonomous driving
Changhe Chen, Mozhgan Pourkeshavarz, Amir Rasouli
International Conference on Robotics and Automation (ICRA 2024)

Learn TAROT with MENTOR: A Meta-Learned Self-supervised Approach for Trajectory Prediction
Mozhgan Pourkeshavarz, Changhe Chen, Amir Rasouli
International Conference on Computer Vision (ICCV 2023)

Looking back on learned experiences for class/task incremental learning
Mozhgan Pourkeshavarz, Guoying Zhao, Mohammad Sabokrou
International Conference on Learning Representations (ICLR 2022, Spotlight)

TrACT: A Training Dynamics Aware Contrastive Learning Framework for Long-tail Trajectory Prediction
Junrui Zhang, Mozhgan Pourkeshavarz, Amir Rasouli
IEEE Intelligent Vehicles Symposium (IV 2024)

Stacked cross-modal feature consolidation attention networks for image captioning
Mozhgan Pourkeshavarz, Shahabedin Nabavi, Mohsen Ebrahimi Moghaddam, Mehrnoush Shamsfard
Multimedia Tools and Applications (2022)